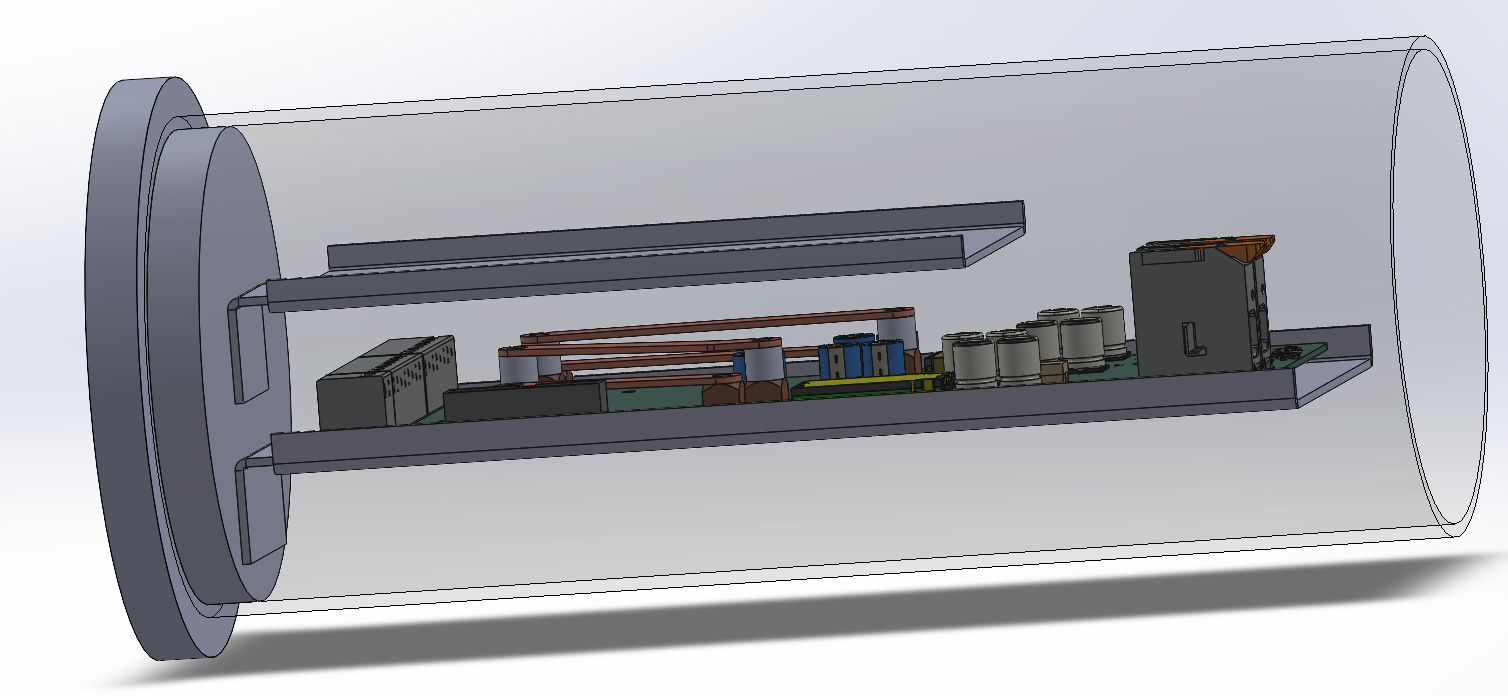
Basilisk Robotics
Developing an autonomous underwater robot for hull cleaning and inspection.
Leading the electrical and software architecture, including embedded control,
sensing, onboard compute, autonomy, and ROS 2 integration.
ROS 2, C++, STM32, Embedded Linux, Computer Vision
View Project →

CMU Racing Electronics
Designed and tested embedded control and data-acquisition hardware for
CMU Racing's electric race car, including STM32-based PCBs, vehicle
networking, sensing, and real-time firmware.
Altium Designer, STM32, FreeRTOS, CAN
View Documentation →
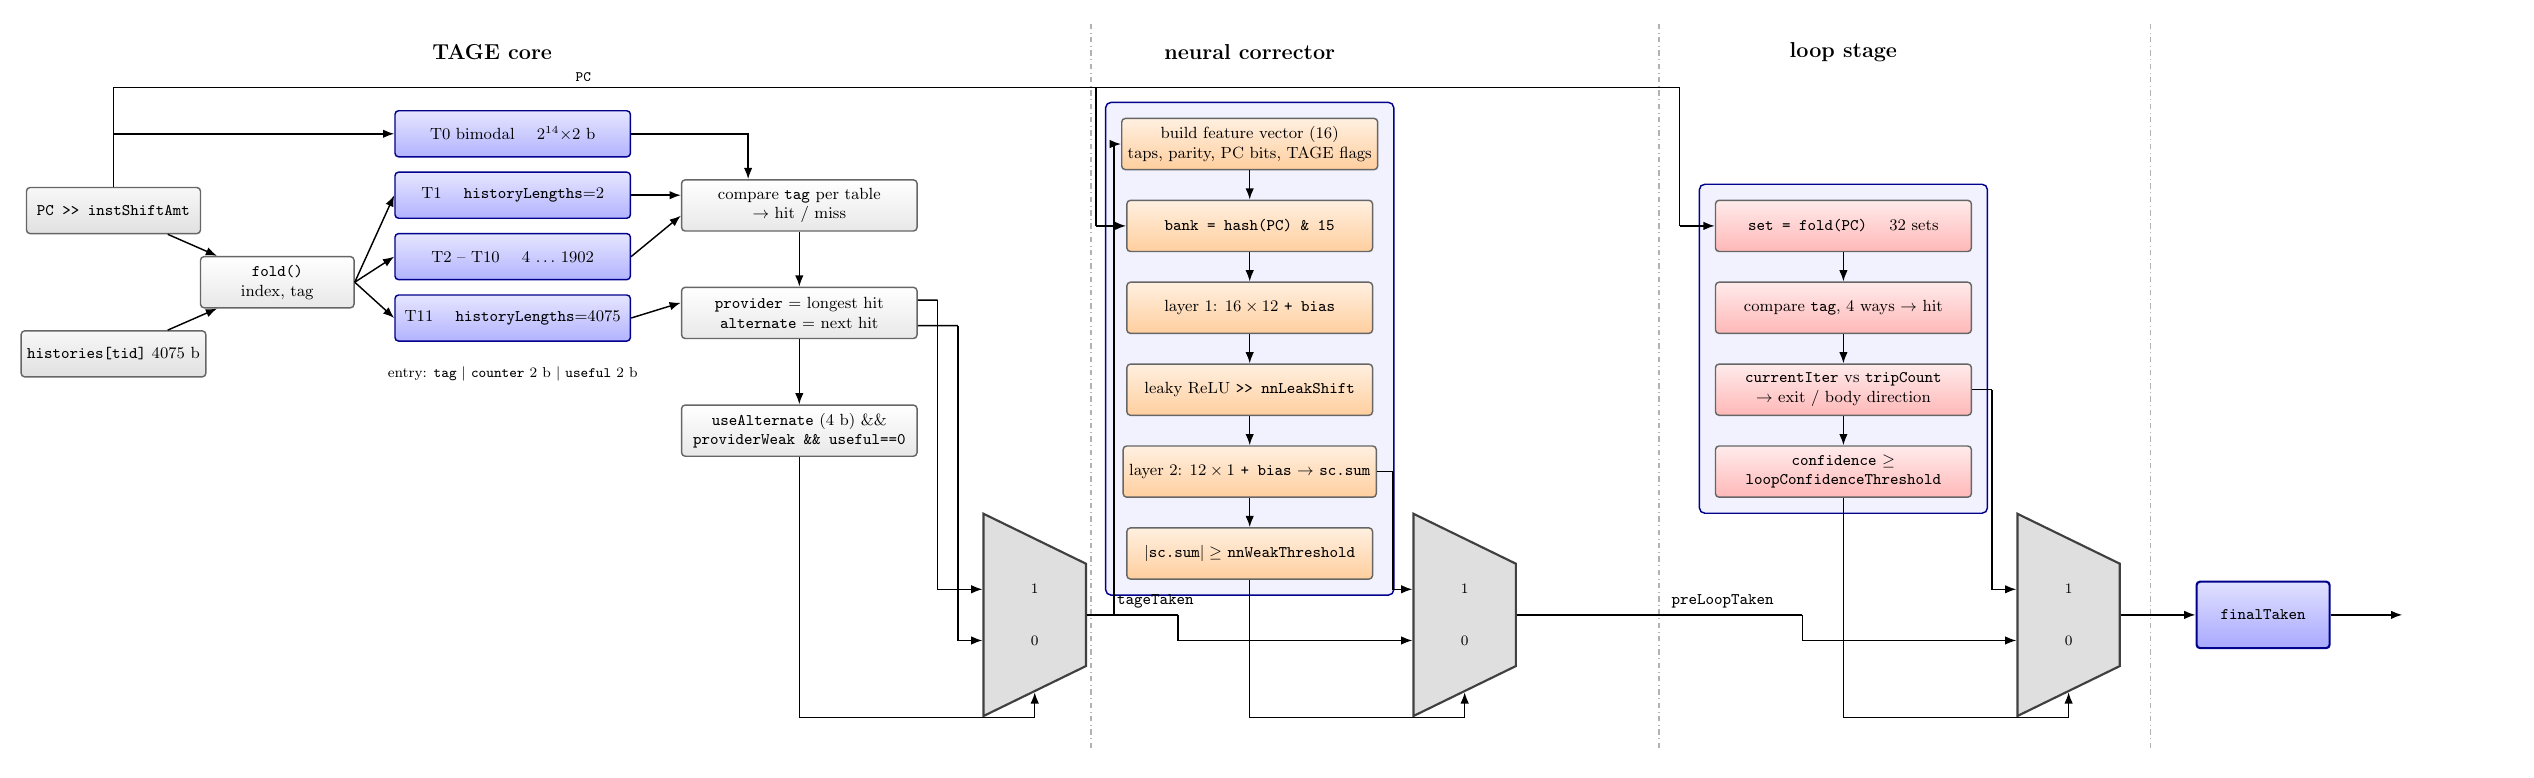
Advanced Branch Prediction
Designed and optimized branch predictors under a 64 KiB hardware budget,
exploring TAGE-SC, TAGE-NN, and TAGE-NN-L architectures with statistical
and neural correctors on SPEC workloads.
C++, gem5, TAGE, Neural Networks, Computer Architecture
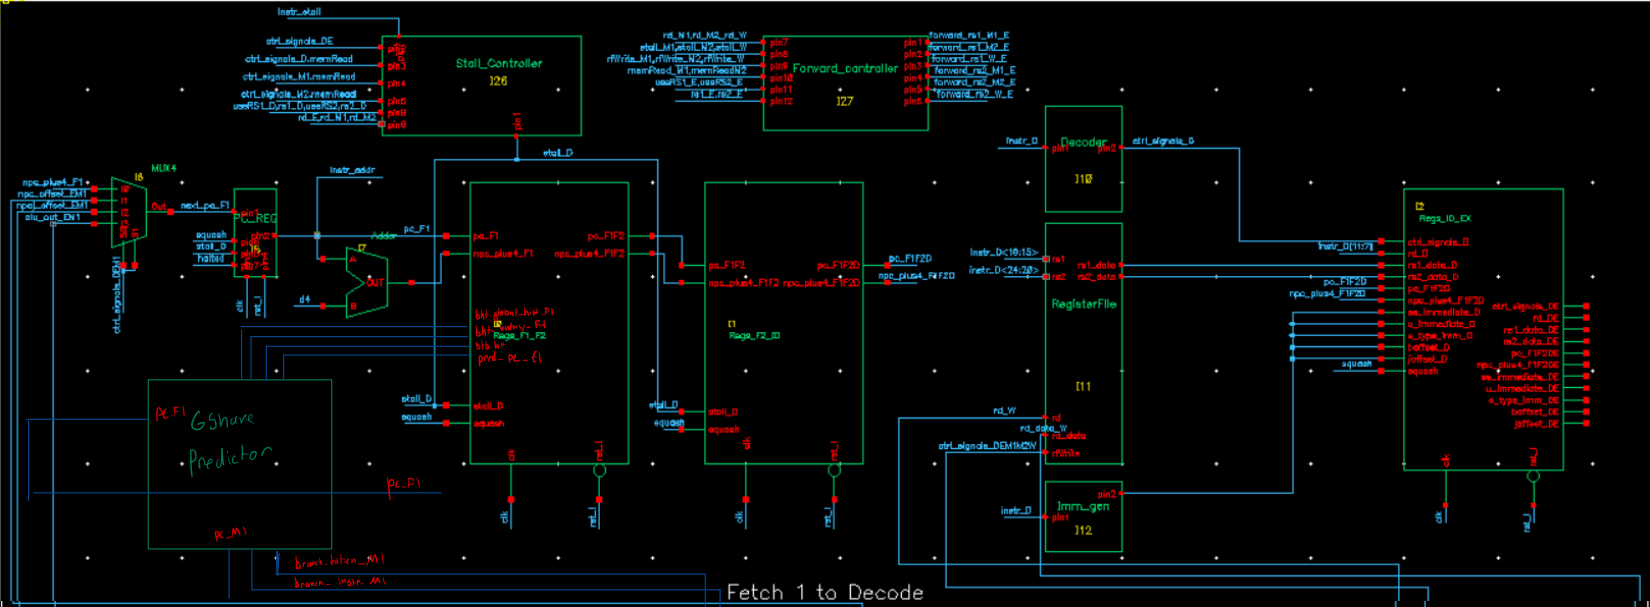
Pipelined RISC-V Processor
Designed a 7-stage RV32I processor with pipelined execution, caching,
hazard handling, and adaptive branch prediction, then synthesized and
evaluated the design for performance.
SystemVerilog, RISC-V, Xilinx Vivado, Computer Architecture
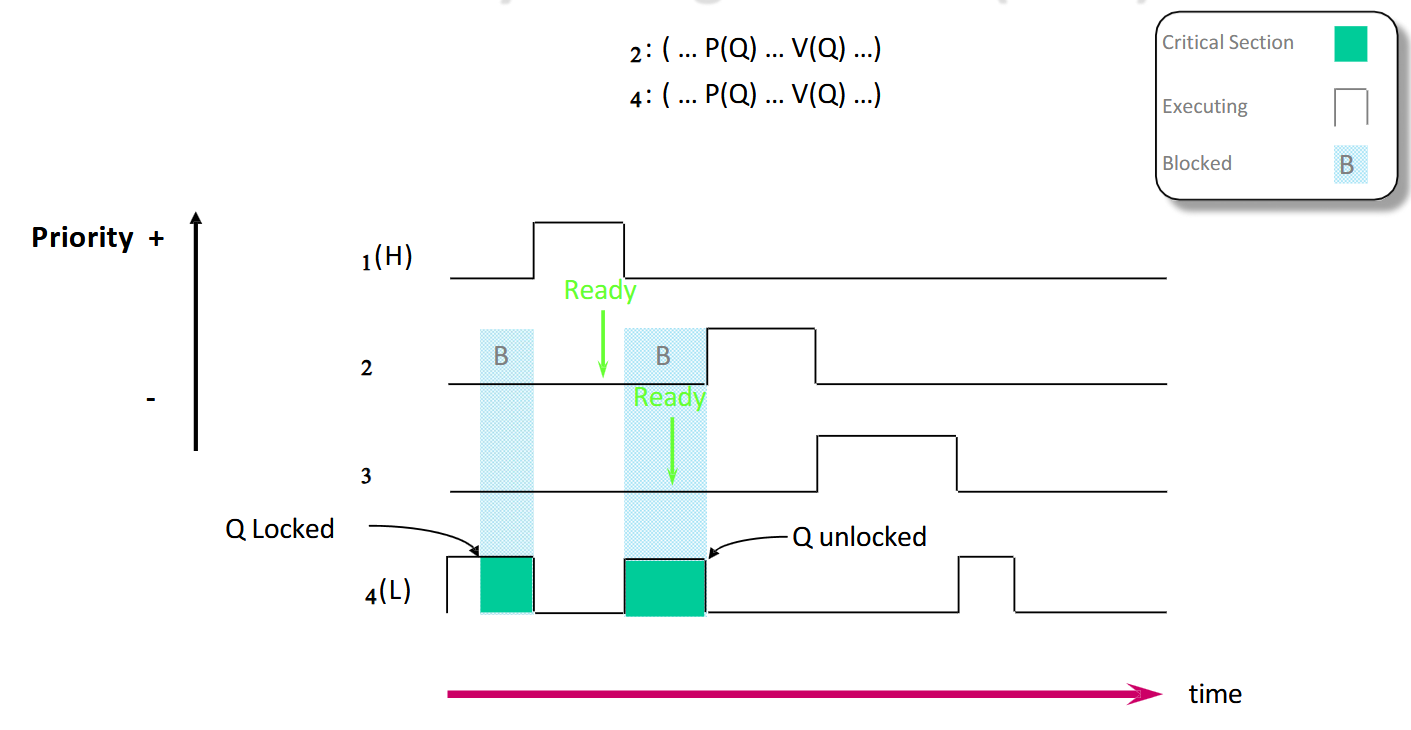
Preemptive Real-Time OS
Built a preemptive embedded operating system for STM32 with
rate-monotonic scheduling, task admission control, execution-time
enforcement, and mutexes with priority-inversion protection.
C, STM32, ARM Cortex-M, Real-Time Systems

Computer Vision
Implemented visual tracking, feature matching, augmented reality,
epipolar geometry, 3D reconstruction, neural networks, and prompt-based
segmentation culminating in 3D object point-cloud reconstruction.
Python, OpenCV, NumPy, PyTorch, Segment Anything

Chron Smartwatch
Building a custom smartwatch with activity and biometric sensing,
environmental sensors, gesture-based wake detection, and Bluetooth
Low Energy connectivity on custom embedded hardware.
C, Zephyr, nRF54L15, BLE, Embedded Systems
View Documentation →
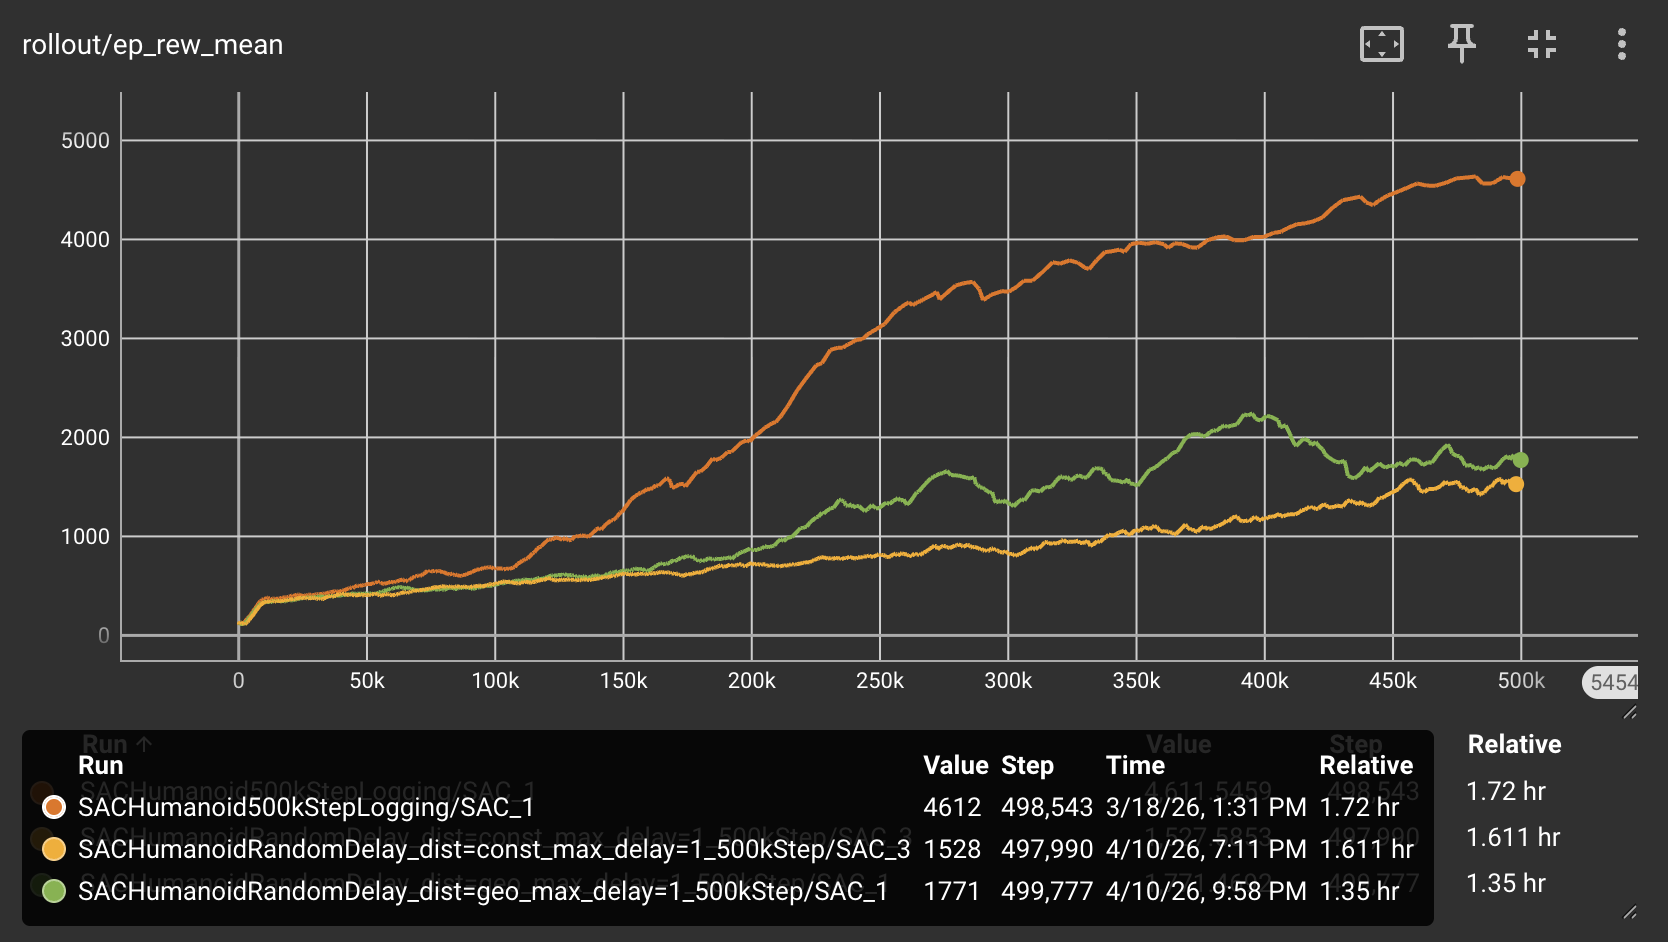
Constrained Reinforcement Learning
Explored reinforcement-learning agents operating under practical
memory, numerical-precision, and inference-latency constraints,
evaluating the tradeoffs between resource usage and policy performance.
Python, PyTorch, Reinforcement Learning

Wake 'n' Shake Alarm
Built an interactive alarm clock that requires completing a cognitive
or physical challenge before it can be dismissed, including memory
games and vision-based exercise recognition.
Raspberry Pi, Python, OpenCV, MediaPipe
View Documentation →

FPGA Pong
Implemented Pong entirely in digital hardware, including game logic,
real-time video generation, user input, and a VGA display interface.
SystemVerilog, FPGA, Xilinx Vivado, VGA

Fun With Robots
Developed labs and starter software for a CMU robotics course covering
sensing, controls, actuation, computer vision, and autonomous robot
navigation.
C++, Arduino, Robotics, Computer Vision
View Course Materials →